
01 Independent roboticist, PhD in robotics and AI
Software that lets robots work reliably in the real world.
I am a senior robotics engineer with many years of experience in software development and a PhD in robotics and AI. I support robotics projects from the first idea to the integrated robot.
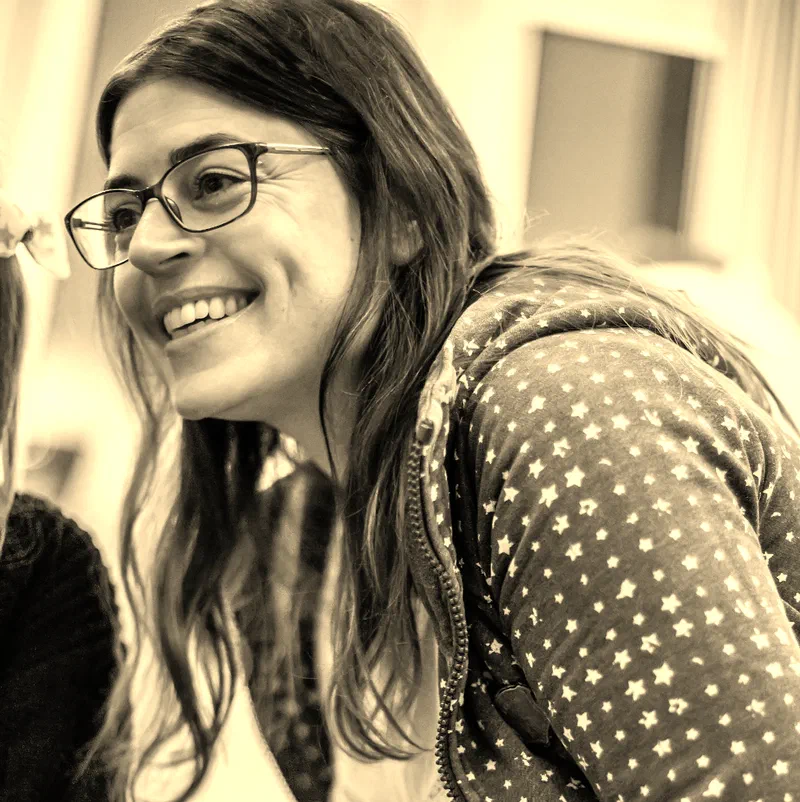
02 About
My passion lies in developing algorithms and quality software that enable robots to operate autonomously in the real world with a high degree of reliability and robustness. This is a broad mission, and I feel privileged to have gained experience in many of the fields involved: computer vision, localization, path and motion planning, navigation, task planning and more. Certainly not least, I bring experience in the building block underneath all of these: software design and development.
I am eager to continue this mission and collaborate on projects involving autonomous robotic systems, on land, on water and in the air. I strongly believe in the power of knowledge transfer, as it brings fresh ideas and perspectives to both sides, so I am also interested in other areas of application for AI.
I have worked as an independent roboticist for most of my career, and currently work closely with b»robotized. As a freelance robotics software engineer and ROS 2 consultant, I can support your project at any stage of its life cycle: initial planning, feasibility studies and prototypes, algorithm and software development, and robot integration. I can also contribute my experience in leading and mentoring small teams of software engineers.
03 Selected work
 2026
AI for Industry Challenge
Human-in-the-loop reinforcement learning for contact-rich cable insertion.
 2024-2025
Robotic cells at Sunrise Robotics
Architecture and core of a robotics stack for simulation-trained robotic cells.
 2019-2023
Autonomous vehicle at TomTom
Simulation, test scenarios and safety analysis for the self-driving test vehicle Trillian.
 2016-2019
World model at Roboception
Perception-based world model for a pick-and-place application, shown at Hannover Messe 2018.
 2011-2015
PhD at UNSW Sydney
Robot capabilities and temporal planning for heterogeneous multi-robot systems.
04 How I work
Expertise
Broad knowledge and a deep understanding of robotics, applied to engineer solutions for complex challenges.
Quality
Carefully crafted software: well structured, thoroughly tested and extensively documented.
Reliability
A reliable partner for robotics software, delivering consistently with prompt and clear communication.
05 Skills
An overview of my core experience. More detail on the experience page.
Robotics
Perception and localization
AI and planning
Simulation and graphics
Software engineering
Every robotics project has its own challenges and opportunities. I look forward to discussing yours: its feasibility, possible solutions, and how my expertise can help you reach your goals.
Get in touch